
Choosing the right motion feedback system can be the difference between a high-precision machine and one plagued by signal noise and positioning errors. You might already know that selecting between Single Track vs Dual Track Magnetic Encoder designs is a major technical hurdle… but which one actually fits your specific application?
I’ve seen too many engineers over-specify their hardware or, worse, compromise on critical accuracy due to a misunderstanding of track architecture. Whether you need the cost-effective simplicity of a single-track setup for basic speed sensing or the high-fidelity quadrature and direction detection provided by dual-track arrays, this guide cuts through the noise.
I’ve broken down the trade
-offs in resolution, cost, and complexity based on real-world engineering constraints. Let’s dive in.
Understanding Magnetic Encoding Fundamentals
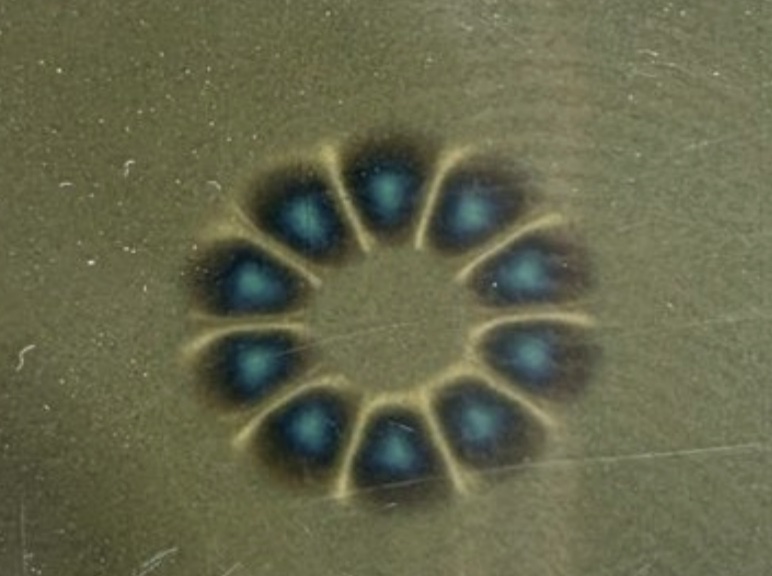
Magnetic encoding serves as the foundation for high-precision feedback in industrial automation. By utilizing multi-pole magnetic rings to convert mechanical rotation into electrical signals, these systems provide reliable non-contact motion monitoring.
Core Principles of Magnetic Sensing
-
- Magnetic Pole Pitch: The physical distance between magnetic poles determines the base resolution. A tighter pole pitch allows for higher density, directly increasing the pulses per revolution (PPR) that a control system can interpret.
- Signal Interpretation: Through the use of Hall-effect or Magnetoresistive (MR) sensor arrays, the system detects the flux change as the ring rotates. These sensors translate the passing north and south poles into clear, measurable waveforms.
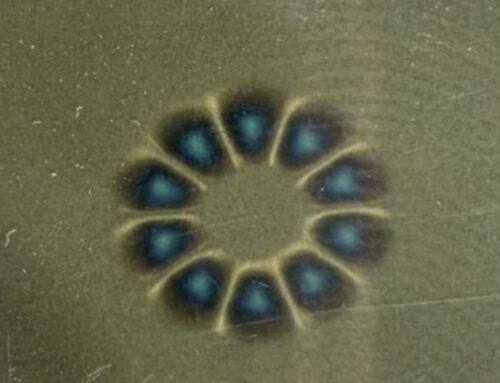
- Precision Magnetization: The integrity of the encoder signal is entirely dependent on the quality of the magnetization process. Consistent, uniform pole strength is required to prevent signal jitter and ensure long-term accuracy in motor feedback loops.
By focusing on controlled manufacturing standards, we ensure that the magnetic field characteristics are optimized for the specific sensor interface, providing a stable foundation for both
speed and position control in demanding industrial environments.
Deep Dive: Single Track Magnetic Encoders
The architecture of a single track magnetic encoder relies on a simplified array where magnetic poles are arranged in a continuous, uniform sequence along the circumference of the ring. This design is highly effective for basic rotational speed sensing applications where absolute position and direction detection are secondary to overall output volume and cost-efficiency.
Key characteristics of single-track arrays include:
-
- Space-Saving Profiles: Due to the single-channel requirement, these systems offer a minimal footprint, making them ideal for compact industrial motor assemblies where axial space is restricted.
- Cost-Efficiency: Simplified magnetization patterns and fewer required Hall-effect sensor components reduce total system BOM costs.
- Signal Output: Provides a straightforward incremental pulse train, which is sufficient for monitoring RPM in non-complex motion control environments.
While these encoders excel in economy and space, they possess inherent limitations in directional sensing. Without a secondary track to provide phase-shifted signals, a single-track system cannot inherently distinguish between clockwise and counter-clockwise rotation. For engineers integrating these into magnetic coupling systems, it is critical to evaluate
if the application requires directionality or if the current architecture aligns with basic speed-feedback needs.
Deep Dive: Dual Track Magnetic Encoders
Dual track magnetic encoders utilize two distinct circular tracks of magnetic poles to generate phase-shifted signals, typically achieving A/B quadrature output. By offsetting these tracks, the sensor array can determine the direction of rotation in addition to speed, providing the high-precision feedback necessary for robotics and advanced industrial motion control.
Functional Benefits of Dual Track Systems
-
- Directional Sensing: Simultaneous monitoring of phase A and phase B signals allows for immediate determination of clockwise or counter-clockwise movement.
- Low-Latency Feedback: Enables real-time tracking, which is critical for maintaining performance in high-speed industrial motor control systems.
- Enhanced Resolution: Quadrature decoding effectively multiplies the base pulse count, allowing for finer control without requiring a proportional increase in physical magnetic pole density.
Comparison of Encoder Architectures
| Feature | Single Track | Dual Track |
|---|---|---|
| Primary Output | Incremental pulses | Quadrature (A/B) pulses |
| Direction Sensing | Not natively supported | Native support |
| Control Complexity | Low | Moderate |
| Ideal Use Case | Basic speed monitoring | High-precision robotics |
Selecting a dual track configuration is necessary when your application demands robust feedback loop optimization and the ability to track positional changes accurately during complex motion sequences. Relying on precision-engineered multi
-pole magnetic rings ensures the signal integrity required for these sophisticated dual-channel sensor arrays.
Technical Comparison: Single vs Dual Track Magnetic Encoder Architectures
Selecting the appropriate track configuration is a balance between required feedback precision and the physical constraints of your motor control system. At NBAEM, we assist engineers in choosing between these architectures based on specific signal integrity and rotational speed sensing needs. Understanding the trade-offs between these two systems is critical for optimizing your non-contact motion feedback loop.
Comparative Analysis Table
| Feature | Single Track | Dual Track |
|---|---|---|
| Signal Output | Incremental / Pulse | A/B Quadrature |
| Directional Sensing | Limited / No | Integrated |
| Complexity | Low | Moderate |
| Cost | Cost-efficient | Higher |
| Resolution | Baseline | Enhanced (via 90° phase shift) |
Key Trade-offs
-
- Footprint: Single track systems offer a compact profile, ideal for space-constrained industrial motor control systems where simple speed monitoring is the priority.
- Complexity: Dual track architectures require more precise magnetic pole alignment to maintain accurate phase-shifted outputs, which is vital for high-precision applications.
- Resolution: While single track provides basic position tracking, dual track configurations effectively double the resolution potential by utilizing quadrature signal output to detect rotational direction and position.
Typical Application Scenarios
-
- Single Track: Best suited for straightforward rotational speed sensing where direction is constant or handled by external logic.
- Dual Track: Essential for high-precision robotics, servo motors, and automated machinery where accurate direction and real-time positioning are critical for feedback loop optimization.
For projects requiring specialized magnetic pole pitch or high-density sensor arrays, we provide custom magnetic ring design
to meet your specific technical tolerances.
Engineering Decision Factors for Magnetic Encoders
When integrating magnetic encoders into motion control systems, design engineers must balance physical constraints with the required magnetic encoder resolution. Proper execution relies on several critical decision factors:
-
- Mechanical and PCB Constraints: Evaluate the radial and axial space available on the motor shaft. The physical dimensions of the multi-pole magnetic rings must be selected to accommodate the clearance required for the sensor array without risking mechanical interference.
- Matching Pole Counts to Resolution: System resolution is directly proportional to the magnetic pole pitch. Ensure that the pole count on the ring is calibrated to your controller’s input capabilities to prevent signal overflow or insufficient sampling density.
- Environmental Resilience: Magnetic sensors excel in harsh conditions, but the sensor housing and shielding must be rated for industrial exposure to oil, dust, and vibrations. Reliable non-contact motion feedback depends on maintaining a stable air gap between the ring and the sensor, even in high-temperature or high-humidity environments.
- System Integration: Achieving seamless communication with motor controllers and PLCs requires careful attention to quadrature signal output. Standardizing the interface—whether it is TTL, RS422, or proprietary bus protocols—ensures that the incremental encoder technology provides accurate data for the closed-loop feedback system.
Prioritizing these factors during the initial design phase minimizes signal noise and optimizes the reliability of your industrial automation equipment. Working with precise magnetization profiles is essential for maintaining
encoder signal integrity across all operating speeds.
The Value of Custom Magnetic Solutions
In high-precision industrial applications, standard off-the-shelf components often fail to meet the rigorous demands of specialized motor control systems. We prioritize custom magnetic solutions, moving beyond generic specifications to engineer components that match exact project requirements. By controlling the entire process from raw material selection to final assembly, we ensure that every magnetic ring meets the required technical visualizations of the magnetic field necessary for stable operation.
Custom vs. Standard Engineering
-
- Precision: Standard components offer general tolerances, whereas our custom design focuses on specific mechanical and electrical fit.
- Pole-Pitch Accuracy: We calculate and manufacture specific pole-pitch configurations to ensure optimal signal output for your sensor array.
- Magnetization Quality: Our internal production lines allow for high-accuracy magnetization, minimizing signal jitter and maximizing reliability.
Comparison of Engineering Approaches
| Feature | Standard Components | Custom Magnetic Solutions |
|---|---|---|
| Tolerance | General industrial standard | Tailored to application limits |
| Flexibility | Limited to catalog sizes | Fully customizable dimensions/pole counts |
| Performance | Basic signal integrity | Optimized for high-resolution feedback |
| Integration | Requires system adaptation | Engineered to match system interfaces |
Quality assurance is integrated into our workflow. Every custom magnetic ring undergoes rigorous testing for field strength consistency and geometric precision, ensuring that the sensor feedback loop remains reliable even in harsh environments. Collaborating early in the design phase allows us to
optimize the magnetic pole density and layout, directly impacting the precision of your motion control system.
Frequently Asked Questions Regarding Magnetic Encoder Systems
Industrial feedback systems often require specific configurations to meet operational demands. Below are common technical inquiries regarding the implementation of single and dual-track magnetic sensing.
Can I upgrade from single to dual track without changing the sensor?
Typically, no. A dual-track system requires a sensor array capable of reading two distinct magnetic patterns simultaneously to generate quadrature signals. Replacing the magnetic ring with a dual-track version while maintaining a single-track sensor will result in a loss of phase-shifted data, rendering the upgrade ineffective.
How does magnetic ring diameter impact resolution?
Resolution is directly linked to the number of pole pairs that fit along the circumference of the ring. A larger magnetic encoder ring provides a greater physical distance for magnetization, allowing for a higher density of poles. This increases the base pulse count per revolution, directly enhancing the native resolution of the feedback system.
What role does signal interpolation play in encoder performance?
Interpolation electronically divides the base magnetic signals into smaller increments. This process artificially increases the effective resolution of the encoder beyond the physical pole count. While effective, the quality of the interpolation depends heavily on the signal integrity provided by the high-precision magnetization of the ring.
Why is non-contact feedback preferred in industrial environments?
Non-contact magnetic sensing eliminates mechanical wear associated with traditional optical or contact-based encoders. By utilizing a durable, multi-pole magnetic ring, these systems maintain signal accuracy and reliability even in environments exposed to dust, oil, moisture, or high
vibration, which are common in motor control and robotics applications.
 English
 German
 Vietnamese
 Spanish (Mexico)
 Russian
 Turkish
 Polish
 Hindi
 Thai
 Malay
 Korean
 Japanese
 French
 Czech
 Danish
 Dutch
 Finnish
 Italian
 Portuguese (Brazil)
 Portuguese (Portugal)
 Slovenian
 Ukrainian
 Hebrew
 Scottish Gaelic
 Hungarian
 Tagalog
 Spanish (Spain)
 Serbian
 Indonesian
 Slovak
 Dutch (Belgium)
 Persian
 Arabic
 Romanian
 Estonian
 Greek
 Bulgarian
Leave A Comment