
In industrial robots, collaborative robots, servo motors, and precision automation systems, accurate position feedback is essential for reliable motion control.
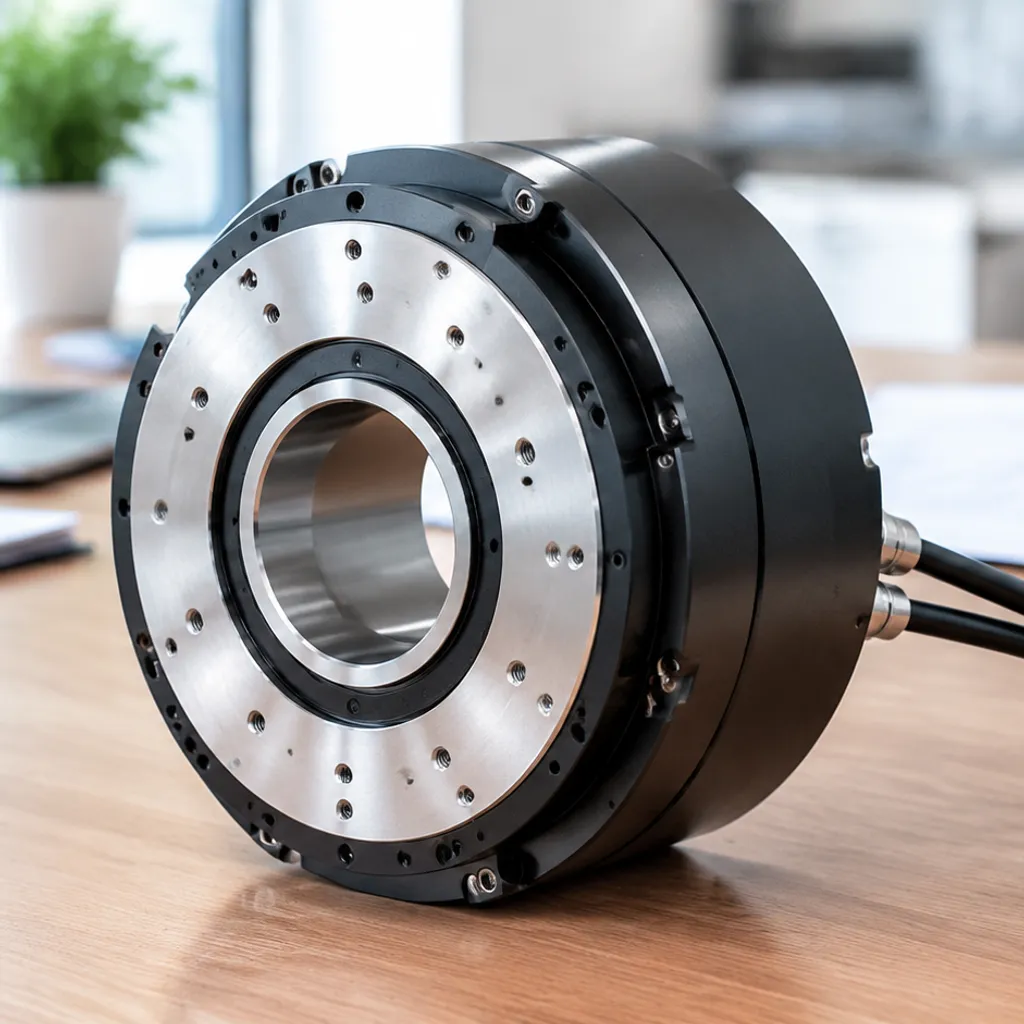
A magneettinen kooderin rengas is a critical component in many rotary encoder systems. By generating a precisely defined magnetic pole pattern, the ring allows magnetic sensors to detect rotational position, speed, and direction without physical contact.
However, as robotic systems become more compact and operate at higher power densities, thermal stability has become an increasingly important design consideration.
During continuous operation, heat generated by motor windings, bearings, and surrounding equipment can raise the temperature of the encoder assembly. Under these conditions, changes in magnetic field strength, mechanical dimensions, and sensor characteristics may affect encoder performance.
In some cases, irreversible magnetic losses can also occur, particularly when the magnetic material is exposed to unfavorable combinations of temperature and external demagnetizing fields.
Two commonly used materials for magnetic encoder rings are injection-molded ferrite magnets ja rubber-bonded ferrite magnets.
How do these materials respond to elevated temperatures? What causes magnetic signal degradation? And how can engineers improve encoder reliability in demanding robotic applications?
This article explores the underlying mechanisms and practical solutions.
Understanding Magnetic Encoder Rings in Robotic Applications
A magnetic encoder ring typically consists of a multipole magnetized ring mounted on a rotating shaft or motor component.
As the ring rotates, alternating north and south magnetic poles generate a changing magnetic field that is detected by Hall-effect sensors, magnetoresistive sensors, or other magnetic sensing technologies.
The sensor electronics convert these magnetic signals into information about rotational position, speed, and direction.
Magnetic encoder systems offer several advantages:
- Non-contact position and speed measurement
- Resistance to dust, oil, and certain environmental contaminants
- Compact construction suitable for integrated motor designs
- Flexible magnetic pole configurations
- Potentially cost-effective solutions for high-volume production
For robotic joints and servo motors, consistent magnetic field distribution is particularly important because signal distortion can influence position estimation and control accuracy.
Although the magnetic ring is a relatively small component, its material properties and magnetization quality can significantly influence overall encoder performance.
Injection-Molded Ferrite vs. Rubber Magnetic Encoder Rings
2.1 Injection-Molded Ferrite Magnetic Rings
Injection-molded ferrite magnets are manufactured by combining hard ferrite magnetic powder with a thermoplastic binder, such as polyamide (PA) or polyphenylene sulfide (PPS).
The compound is processed through injection molding to produce complex shapes with repeatable dimensions.
Key advantages include:
- Good dimensional repeatability
- Flexible geometries and integrated mechanical features
- Suitable production efficiency for large quantities
- Precise multipole magnetization capability
- Material options for different thermal and mechanical requirements
Injection-molded ferrite magnetic rings are commonly considered for motor feedback systems, automotive sensors, and industrial encoder applications.
However, their operating temperature capability depends on both the ferrite magnetic powder and the polymer binder.
For example, a PPS-based magnetic compound may provide better high-temperature dimensional stability than certain conventional polyamide-based compounds.
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
Key advantages include:
- cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
- cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
- cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
- cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
- cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
| Ominaisuus | cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits | cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits |
| cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits | cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits | cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits |
| Joustavuus | cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits | cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits |
| cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits | cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits | cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits |
| cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits | Excellent for molded geometries | Suitable for flexible rings and strips |
| High-temperature capability | Depends on polymer grade and compound | Depends on elastomer formulation |
| Multipole magnetization | Saatavilla | Saatavilla |
| Typical selection priority | Precision geometry and integrated design | Flexibility and assembly convenience |
Neither material is universally superior. The appropriate choice depends on the encoder design, thermal environment, required signal quality, and manufacturing constraints.
What Happens to Magnetic Encoder Rings at High Temperatures?
Temperature affects magnetic encoder performance through several different mechanisms.
Importantly, a reduction in magnetic field strength at elevated temperature does not automatically mean that permanent demagnetization has occurred.
3.1 Reversible Magnetic Changes
Hard ferrite magnets generally exhibit a negative temperature coefficient of remanence (Br).
This means that their remanent magnetic flux density typically decreases as temperature increases.
As the magnet cools, the reversible portion of this magnetic change is recovered.
For a magnetic encoder ring, this behavior can result in a lower magnetic field amplitude at the sensor during high-temperature operation.
Whether this affects position accuracy depends on the sensor architecture, signal-processing method, available magnetic field margin, and system calibration.
3.2 Irreversible Demagnetization
Irreversible demagnetization occurs when the magnetic operating conditions cause a permanent reduction in magnetization that is not recovered simply by returning to the original temperature.
The risk depends on several factors:
- Magnetic material characteristics
- Magnet geometry and operating point
- External magnetic fields
- Temperature history
- Magnetic circuit design
An important distinction is that hard ferrite magnets behave differently from NdFeB magnets.
While NdFeB magnets generally experience decreasing intrinsic coercivity as temperature rises, hard ferrite magnets typically exhibit increasing intrinsic coercivity over their normal operating range.
Therefore, ferrite magnetic encoder rings should not automatically be assumed to have greater irreversible demagnetization risk simply because their temperature increases.
Their actual magnetic stability must be evaluated under the intended operating conditions.
3.3 Thermal Aging of the Polymer Binder
Both injection-molded ferrite and rubber magnetic rings are bonded magnets.
Their magnetic particles are held together by a polymer matrix.
At elevated temperatures, the binder may experience:
- cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
- cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
- cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
- cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
- cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
- cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
- Pole pitch accuracy
- Magnetic field amplitude
- Pole-to-pole consistency
- Harmonic distortion
- Magnetization uniformity
A well-controlled multipole magnetization process can help improve signal consistency and reduce position-related errors.
For precision robotic applications, the magnetic field waveform should be evaluated across the specified operating temperature range.
4.3 Improve Thermal Management
Reducing the actual temperature of the encoder assembly is an effective way to improve reliability.
Possible design measures include:
- Improving heat dissipation around the motor and encoder housing
- Increasing thermal separation from motor windings
- Optimizing ventilation or cooling arrangements
- Reducing heat transfer through mounting structures
- Positioning sensitive encoder components away from concentrated heat sources
The appropriate cooling method depends on the motor configuration, available installation space, and operating environment.
4.4 Maintain a Stable Sensor-to-Magnet Air Gap
The distance between the magnetic ring and the sensing element is a critical design parameter.
Excessive air-gap variation can change the detected magnetic field amplitude and potentially affect signal quality.
Engineers should consider:
- Thermal expansion of the shaft and housing
- Ring concentricity
- Mechanical runout
- Assembly tolerances
- Long-term deformation of the magnetic material
- Adhesive or mounting stability
For precision applications, air-gap variation should be evaluated at both room temperature and maximum operating temperature.
4.5 Provide Adequate Magnetic Signal Margin
The magnetic encoder ring should generate a field that remains within the sensor’s specified operating range under all intended conditions.
A suitable magnetic signal margin helps accommodate temperature-related field changes, manufacturing tolerances, and mechanical variations.
However, increasing magnetic field strength alone does not guarantee better encoder accuracy.
Pole uniformity, signal symmetry, sensor saturation limits, and electronic compensation must also be considered.
Recommended Testing for High-Temperature Magnetic Encoder Rings
For robotic joints and precision servo applications, evaluating magnetic performance only at room temperature is insufficient.
A more comprehensive validation program should consider the following tests.
| cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits | cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits |
| cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits | cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits |
| cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits | cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits |
| cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits | cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits |
| cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits | cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits |
| cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits | cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits |
| cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits | cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits |
| cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits | cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits |
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
- cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
- cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
- What magnetic pole count and pole pitch are required?
- What magnetic field amplitude does the sensor require?
- What are the ring dimensions and installation tolerances?
- Is a rigid or flexible magnetic ring preferred?
- What are the required encoder accuracy and service life?
For applications requiring complex geometries and stable mechanical integration, injection-molded ferrite may be a suitable solution.
For applications that benefit from flexibility or specific mounting arrangements, rubber-bonded ferrite may be considered.
In either case, the final selection should be based on measured magnetic performance, mechanical compatibility, and thermal validation.
Magnetic Encoder Ring Solutions from NBAEM
At NBAEM, we support customers with magnetic material selection and customized magnetic components for motor sensing, industrial automation, and motion-control applications.
Depending on the application requirements and manufacturing feasibility, our magnetic solutions can include:
- Injection-molded ferrite magnetic rings
- Rubber-bonded ferrite magnetic rings
- Customized multipole magnetization
- Magnetic components with application-specific dimensions and pole configurations
- Technical support for material and magnetic design evaluation
For high-temperature applications, we recommend reviewing the operating temperature, magnetic field requirements, dimensional tolerances, and expected service conditions before selecting a material.
This approach helps customers identify suitable magnetic solutions and establish appropriate validation requirements.
Yhteenveto
High-temperature performance is an important consideration in magnetic encoder ring design, particularly for robotic joints, servo motors, and continuously operating industrial equipment.
Although elevated temperatures can reduce the magnetic field strength of ferrite magnets, not every temperature-related signal change represents irreversible demagnetization.
Magnetic material properties, polymer binder stability, mechanical deformation, sensor characteristics, and magnetic circuit design can all influence encoder performance.
By selecting suitable magnetic compounds, optimizing multipole magnetization, controlling the sensor air gap, and conducting appropriate thermal testing, engineers can improve the reliability of magnetic encoder systems.
Looking for a customized magnetic encoder ring for your motor or robotics application?
Contact NBAEM at www.nbaem.com to discuss your magnetic material, dimensions, pole configuration, and operating temperature requirements.
Frequently Asked Questions (FAQ)
Q1: Can a magnetic encoder ring lose magnetism at high temperatures?
Yes, magnetic field strength can decrease as temperature increases. However, this change is often reversible. Permanent magnetic loss depends on the magnetic material, operating conditions, and exposure to demagnetizing fields.
Q2: Which is better for high-temperature applications: injection-molded ferrite or rubber magnets?
Injection-molded ferrite with an appropriate high-temperature polymer binder is often preferred when dimensional stability and rigid mechanical integration are important. Rubber magnets may be suitable when flexibility is required, provided their thermal and mechanical performance meets the application requirements.
Q3: What is the maximum operating temperature of a magnetic encoder ring?
There is no universal maximum temperature. The operating limit depends on the magnetic compound, binder, geometry, mounting method, and application environment. Each design should be evaluated against its specified continuous operating temperature.
Q4: How can engineers prevent magnetic encoder signal drift?
Engineers can improve stability by selecting suitable magnetic materials, maintaining a consistent sensor-to-magnet air gap, optimizing magnetic pole uniformity, managing heat, and validating the complete encoder system across its operating temperature range.
Reference Links:


 Finnish
 English
 German
 Vietnamese
 Spanish (Mexico)
 Russian
 Turkish
 Polish
 Hindi
 Thai
 Malay
 Korean
 Japanese
 French
 Czech
 Danish
 Dutch
 Italian
 Portuguese (Brazil)
 Portuguese (Portugal)
 Slovenian
 Ukrainian
 Hebrew
 Scottish Gaelic
 Hungarian
 Tagalog
 Spanish (Spain)
 Serbian
 Indonesian
 Slovak
 Dutch (Belgium)
 Persian
 Arabic
 Romanian
 Estonian
 Greek
 Bulgarian


Jätä kommentti